
1 páginas (5 elementos)
Simple simulation of dynamic systems with optional controller - mb10 - Mensajes

A general purpose, simple ODE solver function that uses Euler integration to simulate (possibly non-linear) multi-inputs dynamic systems, with "embedded" provision for state feedback controller.
In its most general form, the function implements a system of the form:
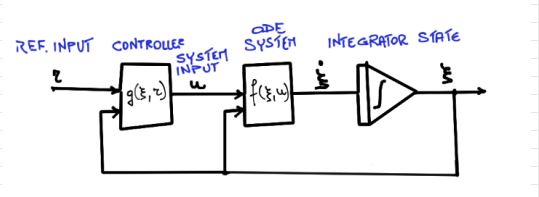
where dot notation indicates time derivative.
A few examples are provided.
DynSys_v01.sm (226,66 KiB) descargado 1771 vez(es).
In its most general form, the function implements a system of the form:
where dot notation indicates time derivative.
A few examples are provided.
DynSys_v01.sm (226,66 KiB) descargado 1771 vez(es).
A 3 usuarios les gustó este mensaje
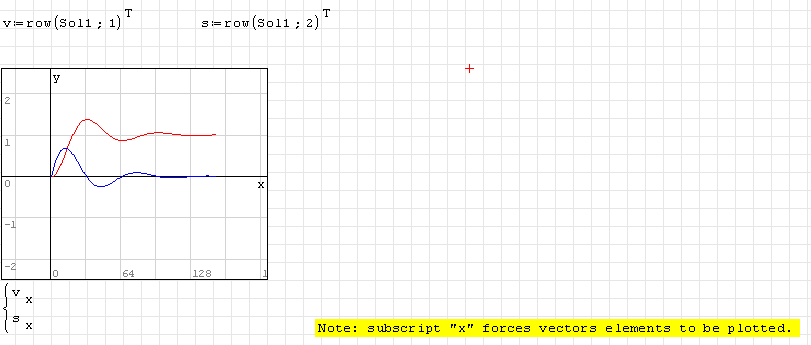
I like the way to plot vectors, was not aware of this.
Technische Mechanik mit SMath Studio: https://link.springer.com/book/10.1007/978-3-658-50592-9
It is an (undocumented?) feature I discovered by chance.
Notice the "staircased" behaviour.
The X-Y plot plug-in has a similar property: in that case it seems that ANY variable name, not just "x", can be used as a subscript to obtain vector plot.
Notice the "staircased" behaviour.
The X-Y plot plug-in has a similar property: in that case it seems that ANY variable name, not just "x", can be used as a subscript to obtain vector plot.
A 1 usuarios les gustó este mensaje
Radovan Omorjan 6/10/2013 8:03:00
WroteIt is an (undocumented?) feature.
Not undocumented any more. SVN Activebook updated.
Section 2D plots built-in.sm (36,68 KiB) descargado 1694 vez(es).
Technische Mechanik mit SMath Studio: https://link.springer.com/book/10.1007/978-3-658-50592-9
A 2 usuarios les gustó este mensaje
1 páginas (5 elementos)
- Nuevos mensajes
- Sin mensajes nuevos